JACoP: Joint Alignment for Compliant Multi-Agent Prediction
Abstract
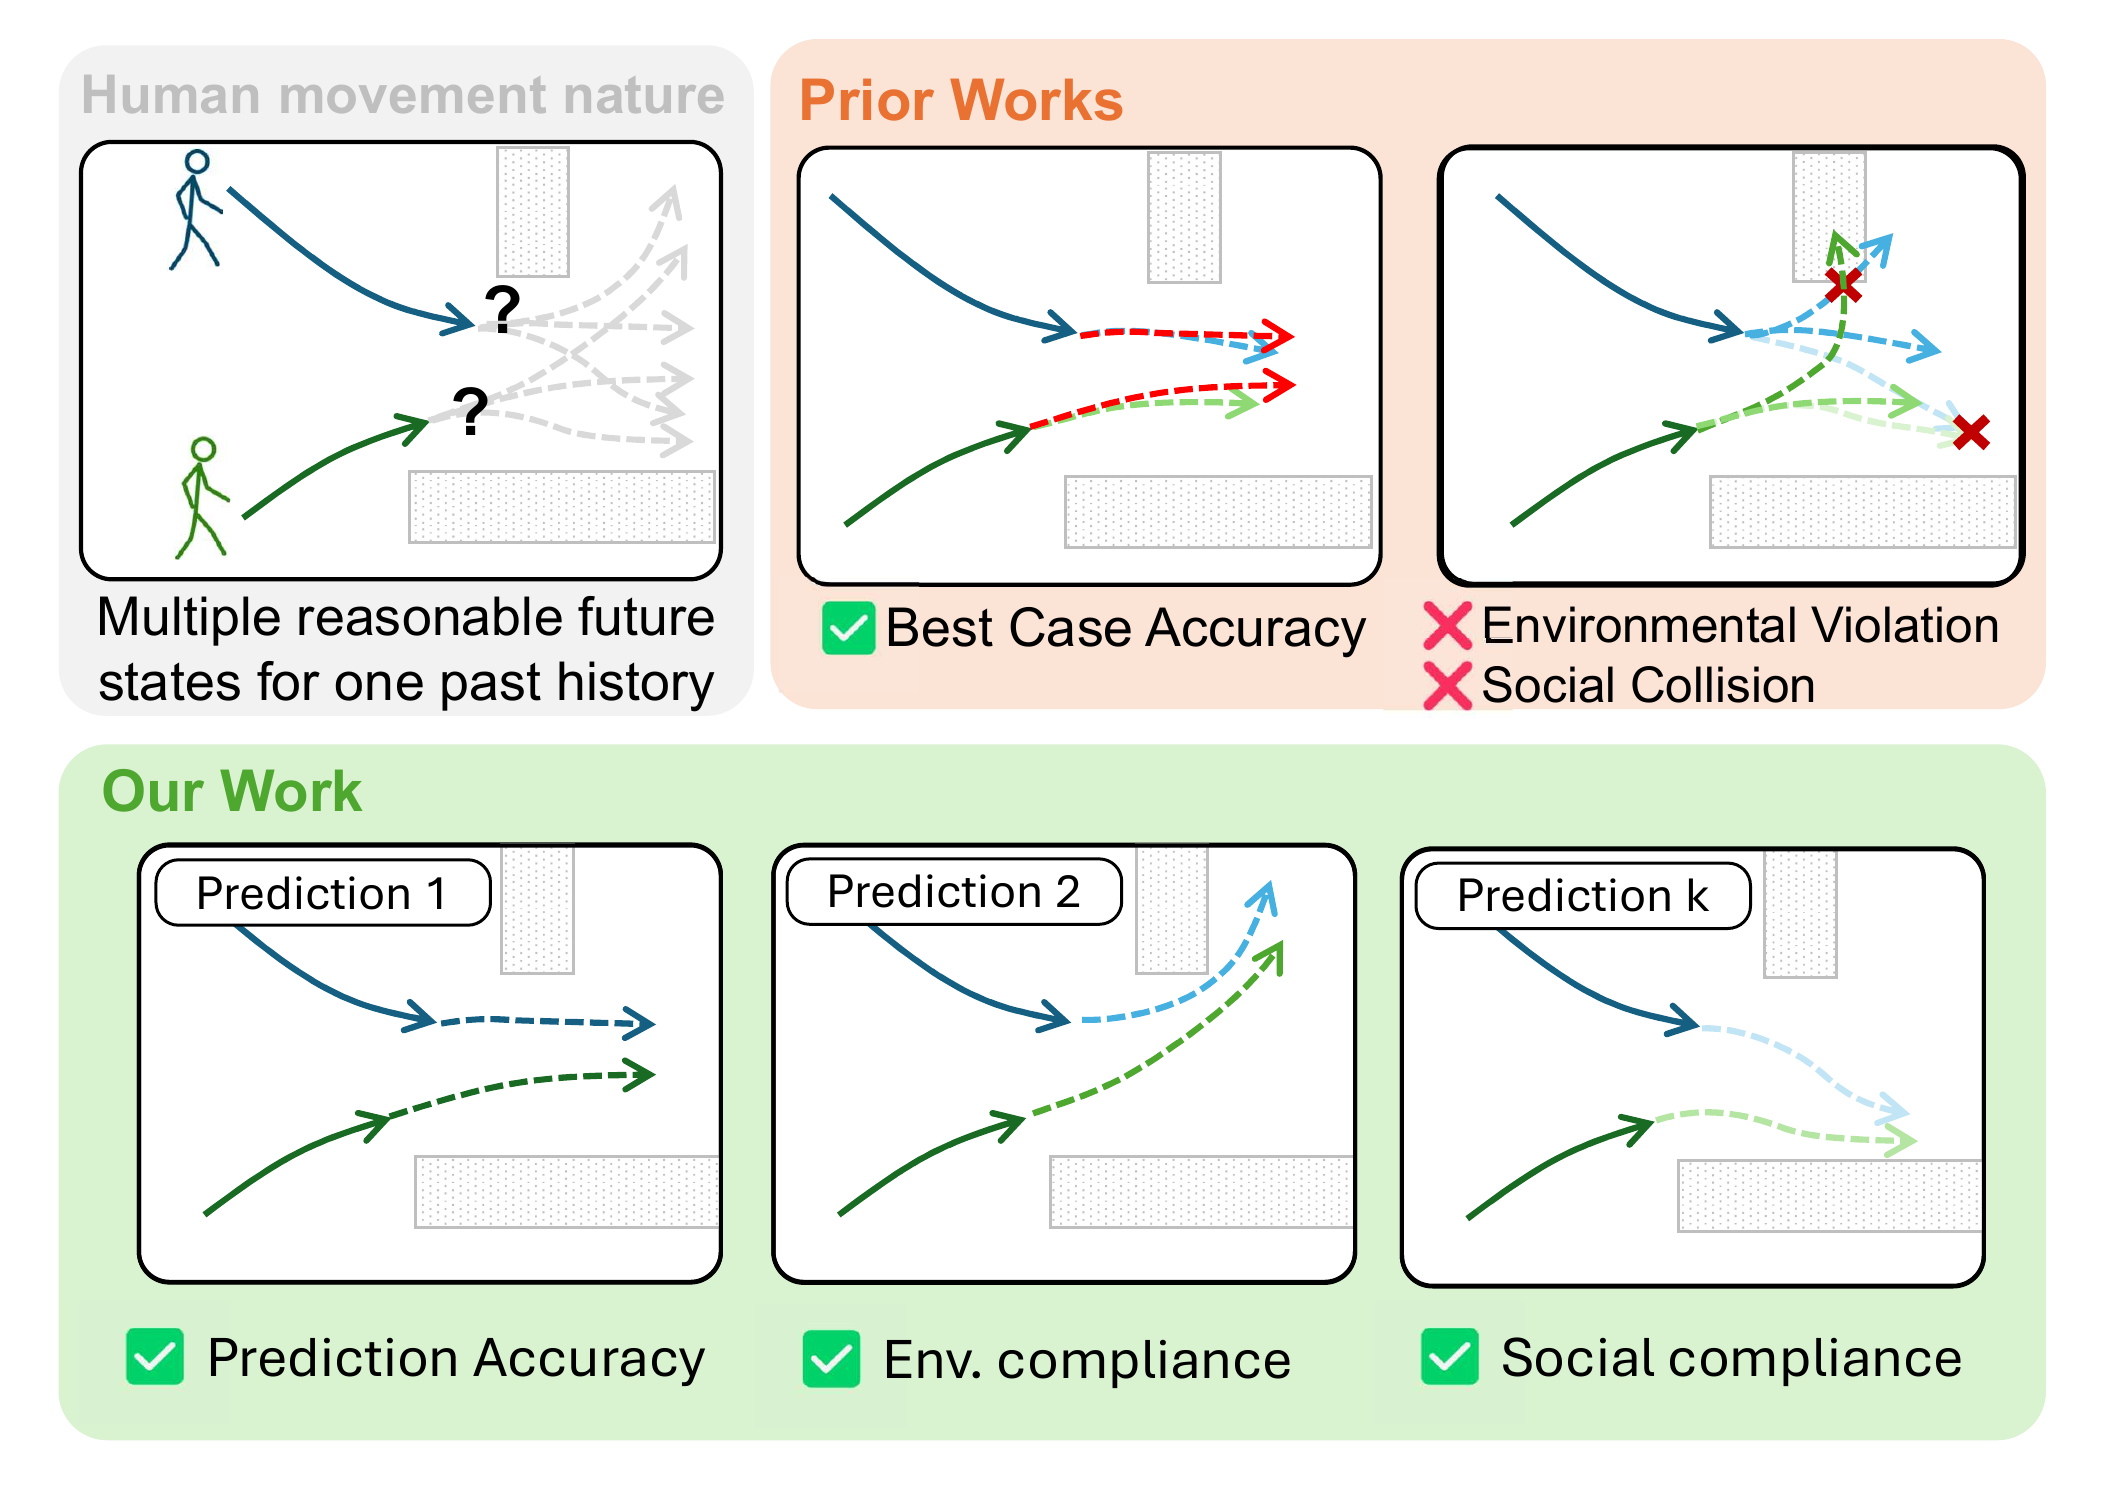
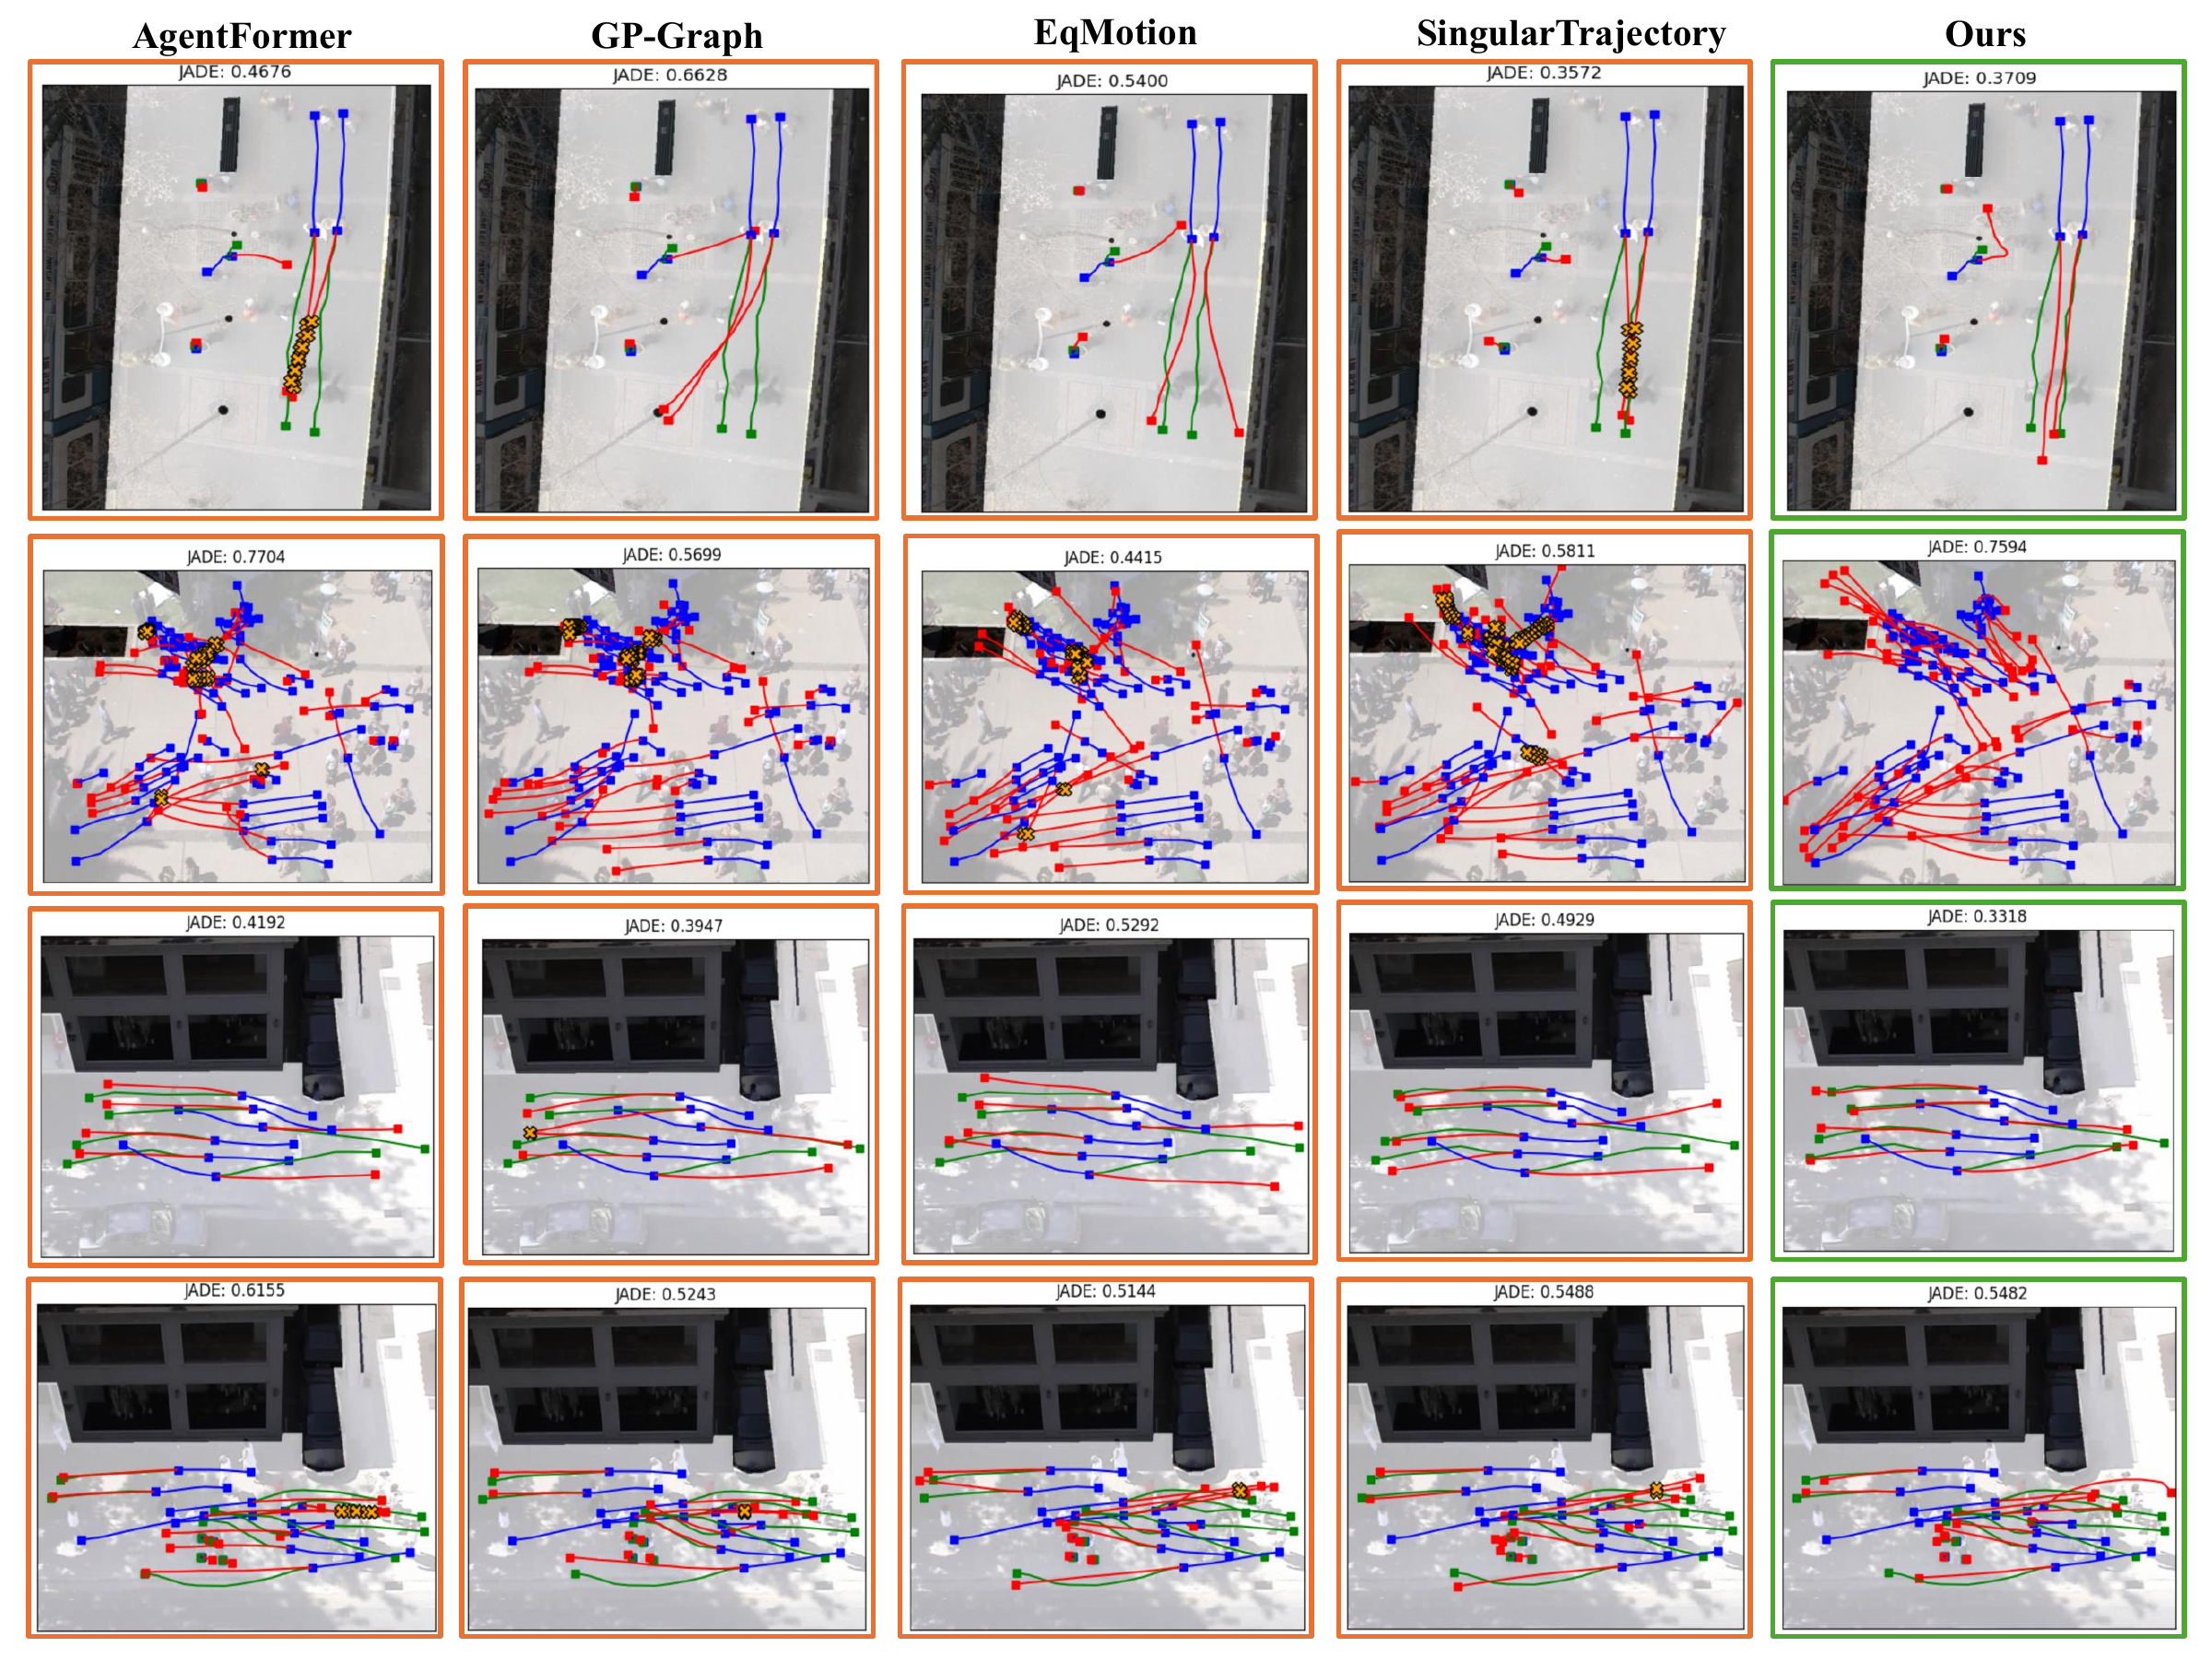
Stochastic Human Trajectory Prediction (HTP) using generative modeling has emerged as a significant area of research. Although state-of-the-art models excel in optimizing the accuracy of individual agents, they often struggle to generate predictions that are collectively compliant, leading to output trajectories marred by social collisions and environmental violations, thus rendering them impractical for real-world applications. To bridge this gap, we present JACoP: Joint Alignment for Compliant Multi-Agent Prediction, an innovative multi-stage framework that ensures scene-level plausibility. JACoP incorporates an Anchor-Based Agent-Centric Profiler for effective initial compliance filtering and employs a Markov Random Field (MRF) based aligner to formalize the joint selection for scene predictions. By representing inter-agent spatial and social costs as MRF energy potentials, we successfully infer and sample from the joint trajectory distribution, achieving prediction with optimal scene compliance. Comprehensive experiments show that JACoP not only achieves competitive accuracy, but also sets a new standard in reducing both environmental violations and social collisions, thereby confirming its ability to produce collectively feasible and practically applicable trajectory predictions.
BibTeX
@inproceedings{liu2026jacop,
  title={JACoP: Joint Alignment for Compliant Multi-Agent Prediction},
  author={Liu, Qingze Tony and Mrdovic, Alen and Li, Danrui and Schwartz, Mathew and Yoon, Sejong and Kapadia, Mubbasir},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  pages={910--919},
  year={2026}
}